
Control System Design for a Self-balancing Motorcycle in MATLAB
This project focuses on designing, testing, and implementing an autonomous or remote control system for a self-balancing motorcycle using the Arduino Engineering Kit. The aim is to create a digital motor controller that effectively balances and steers the motorcycle, which can be demonstrated on the provided hardware.
- Autonomous or remote control capabilities
- Digital motor controller design
- Balancing and steering control
- Live demonstration of the system on the motorcycle hardware
- Self-balancing Motorcycle Kit
- CAD files
- Simulink starter models
- Motorcycle hardware for testing and demonstration purposes
- MATLAB and Simulink
- Arduino IDE
- Arduino support package for MATLAB and Simulink
 Motor Components
 Digital Controller
 Balancing Controller
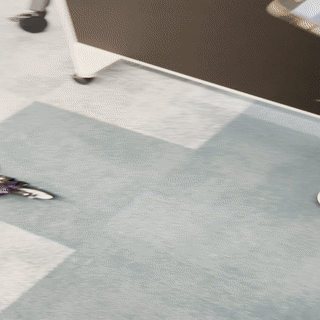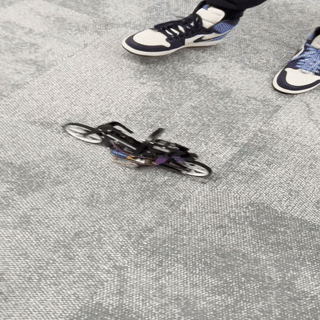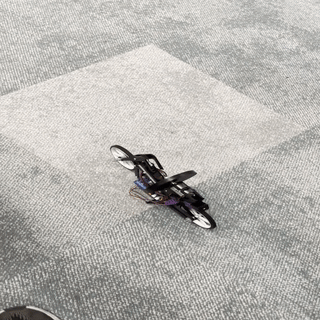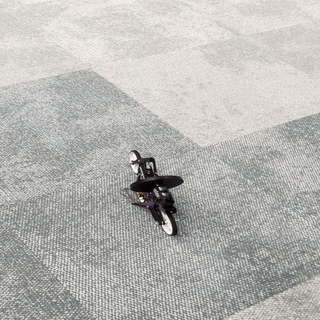
Bike travelling in straight line

Bike balancing on tilted platform

Push Test